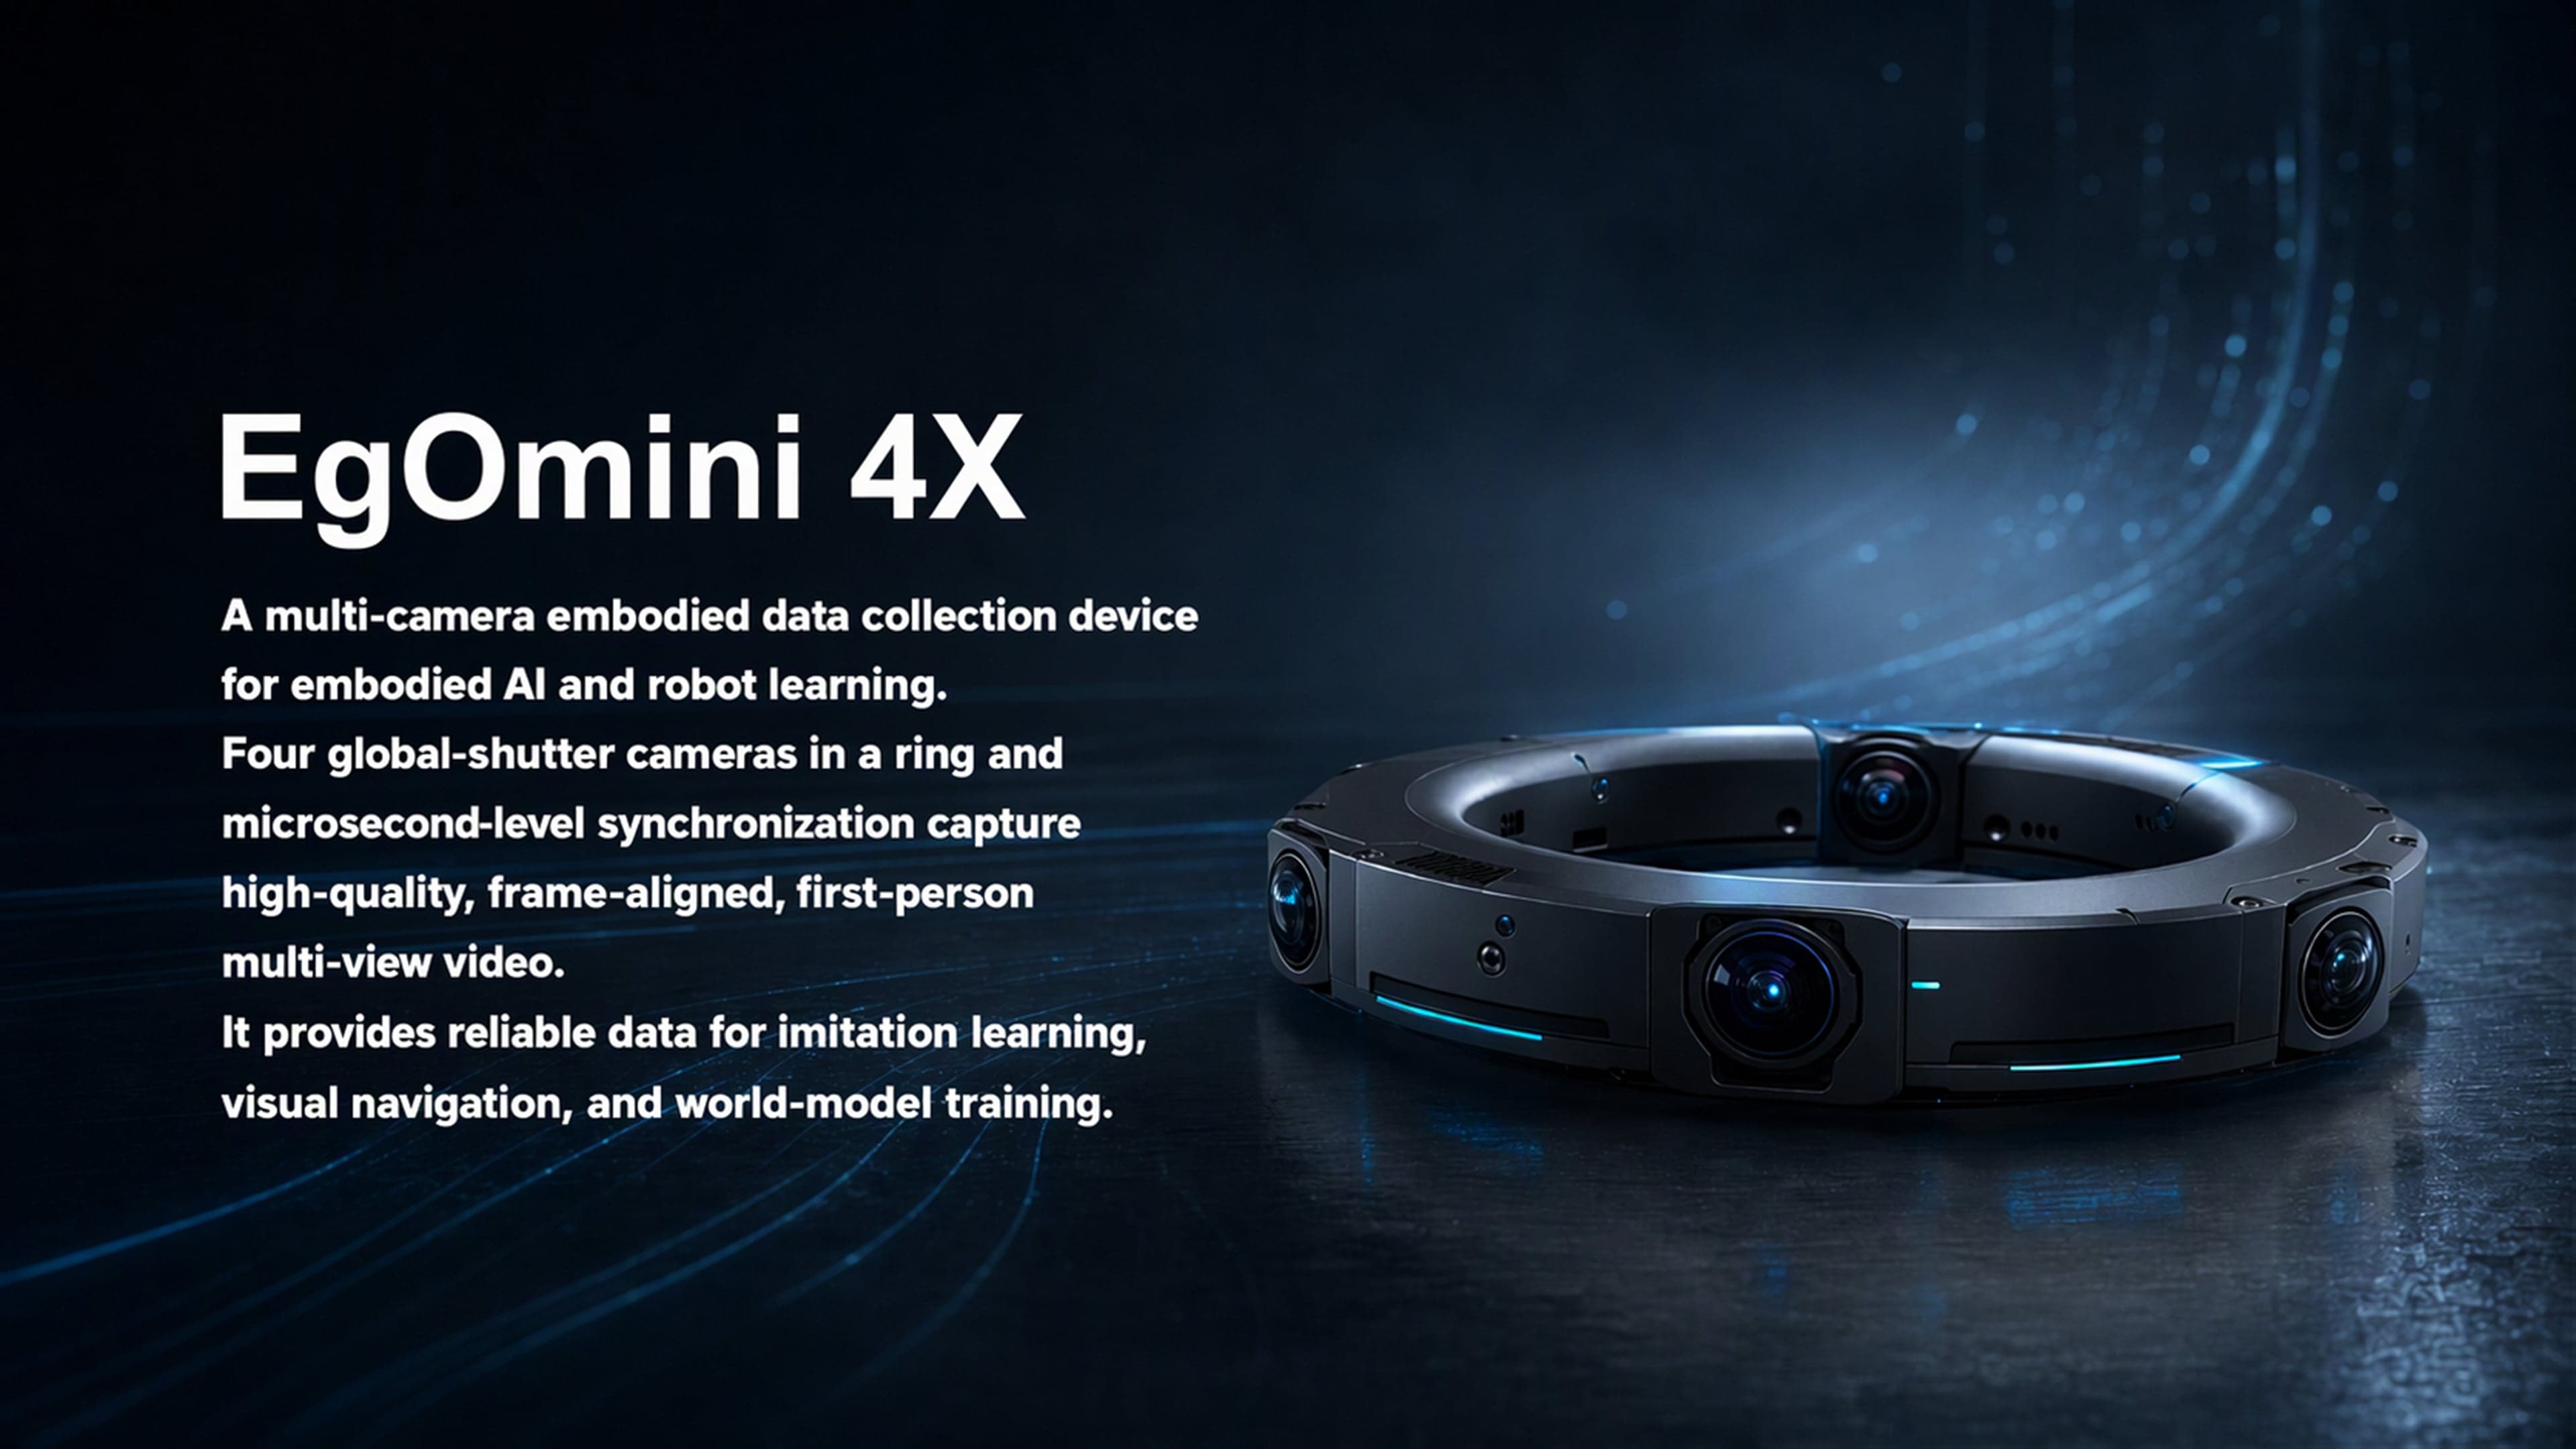
EgOmini 4X
A multi-camera data capture device for embodied AI and robot learning. Four global-shutter cameras in a ring layout, synchronized to the microsecond, reliably capture high-quality, frame-aligned egocentric multi-view video, providing a dependable data foundation for imitation learning, visual navigation, and world model training.
PRODUCT INTRODUCTION
EgOmini 4XMulti-Camera Embodied Data Capture Device
With four global-shutter cameras and microsecond-level synchronization, EgOmini 4X reliably outputs frame-aligned, egocentric multi-view video, ideal for wearable capture, robot-mounted capture, lab scene playback, and other data collection workflows.
- A near-ring multi-camera layout covers forward, side, and partial downward views, preserving more complete first-person task context.
- Synchronized capture combined with local recording reduces the cost of downstream registration, clipping, and pre-training processing.
- TF / SD local recording, USB offload, and Wi-Fi + BLE management form a complete workflow.
PRODUCT PARAMETERS
| Camera | RES @ FPS | Encoding | FOV (D) | FOV (H) | FOV (V) | Distortion |
|---|---|---|---|---|---|---|
| Camera 1 | 1080p @ 30fps | H.264 / H.265 | 194° ±5 | 152.6° ±3 | 121° ±3 | -100% ±5% (@180°) |
| Camera 2 | 1080p @ 30fps | H.264 / H.265 | 187.6° ±5 | 156.4° ±3 | 83.4° ±3 | -100% ±5% (@180°) |
| Camera 3 | 1080p @ 30fps | H.264 / H.265 | 145° ±5 | 120.6° ±3 | 64.2° ±3 | -64.6% ±5% |
| Camera 4 | 1080p @ 30fps | H.264 / H.265 | 200° ±5 | 200° ±5 | 108.2° ±3 | -100% ±5% (@180°) |
Note: The Y value in parentheses after FOV is the corresponding image-height reference; distortion values are calibrated at the indicated field of view. All parameters are subject to measured calibration; ± indicates the engineering tolerance range.
Ring-Shaped Wide-Angle Layout
Four distinct wide-angle modules form near-ring coverage around the body, more fully preserving the operator's viewpoint, environmental context, and partial downward views in first-person tasks.
Built for Fast Motion
Global shutters and microsecond-level synchronization reduce distortion and timing errors during rapid motion and view switching, making the device well suited to real-world motion capture and pre-training processing.
PRODUCT HIGHLIGHTS
- 01QUAD CAMERA ARRAY
Surround Multi-Camera Capture
- Four wide-angle modules form a near-ring field of view covering forward, side, and partial downward areas.
- Preserves more of the first-person action and its environmental context, minimizing missing key viewpoints.
- 02µs-LEVEL SYNC
Closed-Loop Microsecond Sync
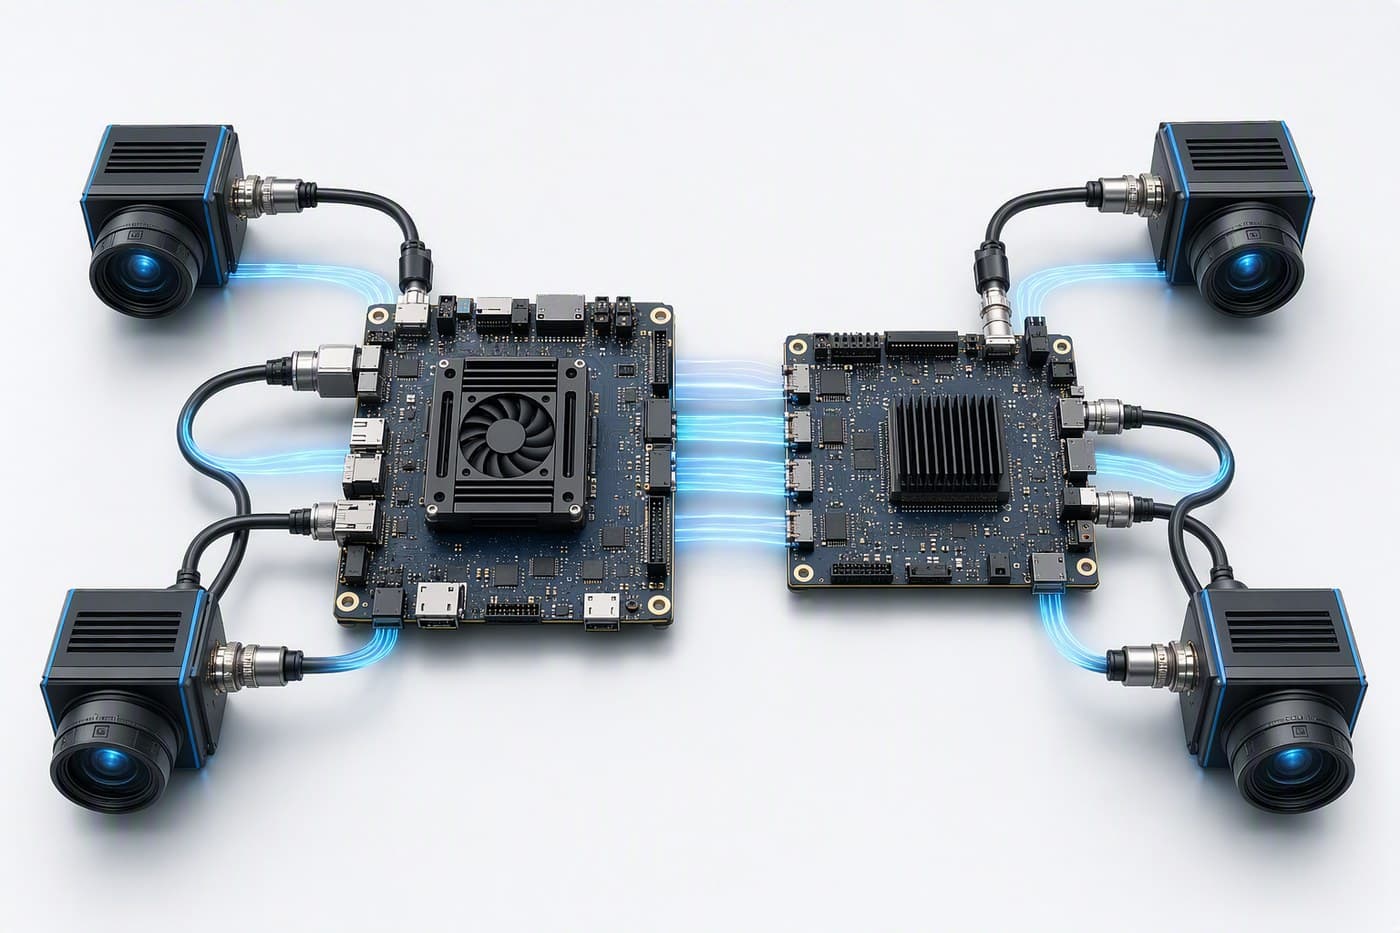
- Unified triggering, recording, and time synchronization keep all views frame-aligned.
- Reduces data cleaning, time alignment, and post-processing costs, fitting right into training data production.
- 03COMPACT DEPLOYMENT
Compact Deployment & Management
- Master-slave coordination and centralized power suit wearable use, robot mounting, and rapid lab deployment.
- Wi-Fi + BLE management reduces on-site operational complexity.
- 04LOCAL DATA PIPELINE
Reliable Data Pipeline
- TF / SD local recording, USB offload, and on-site verification form a complete capture pipeline.
- Balances stable continuous capture with efficient data retrieval across experiment batches.
APPLICATION SCENARIOS
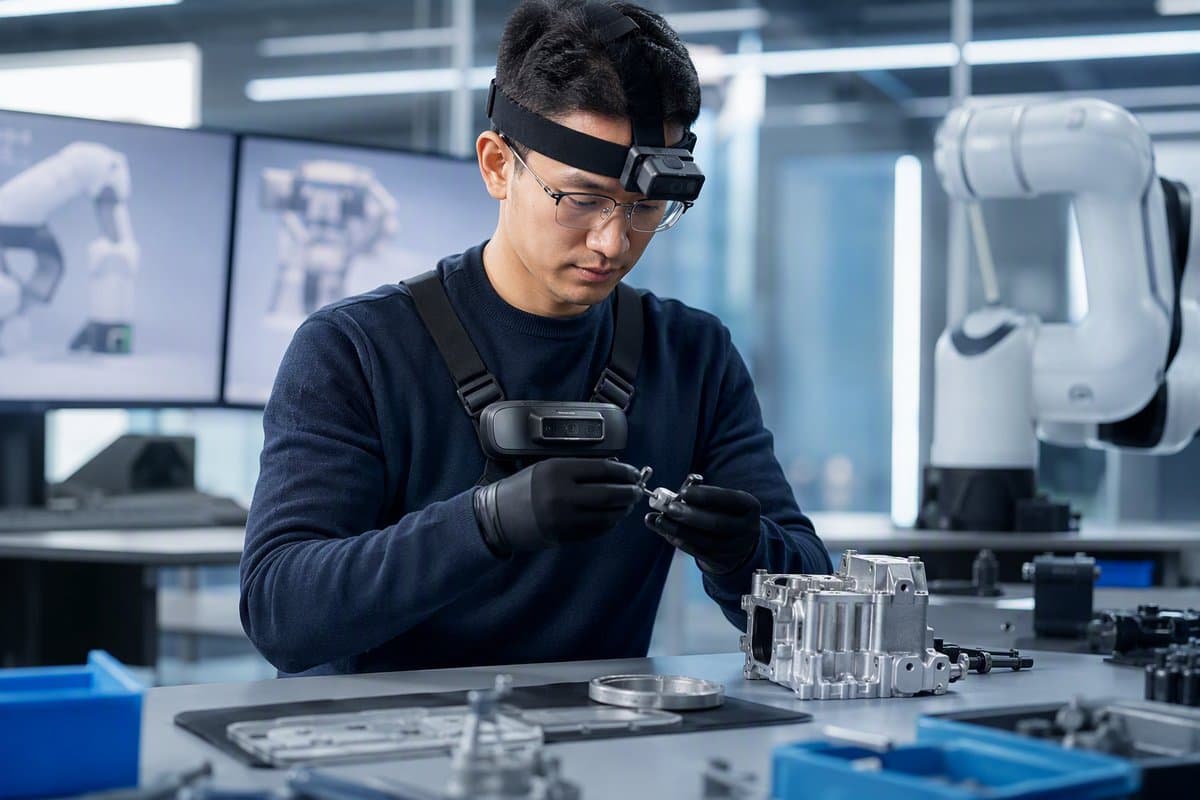
Imitation Learning Data Capture
- Records human operations from multiple first-person views, fully preserving the relationship between hand movements and target objects.
- Ideal for task demonstrations such as grasping, assembly, and tabletop interaction.
- Synchronized multi-view footage reduces downstream registration and clip-selection costs.
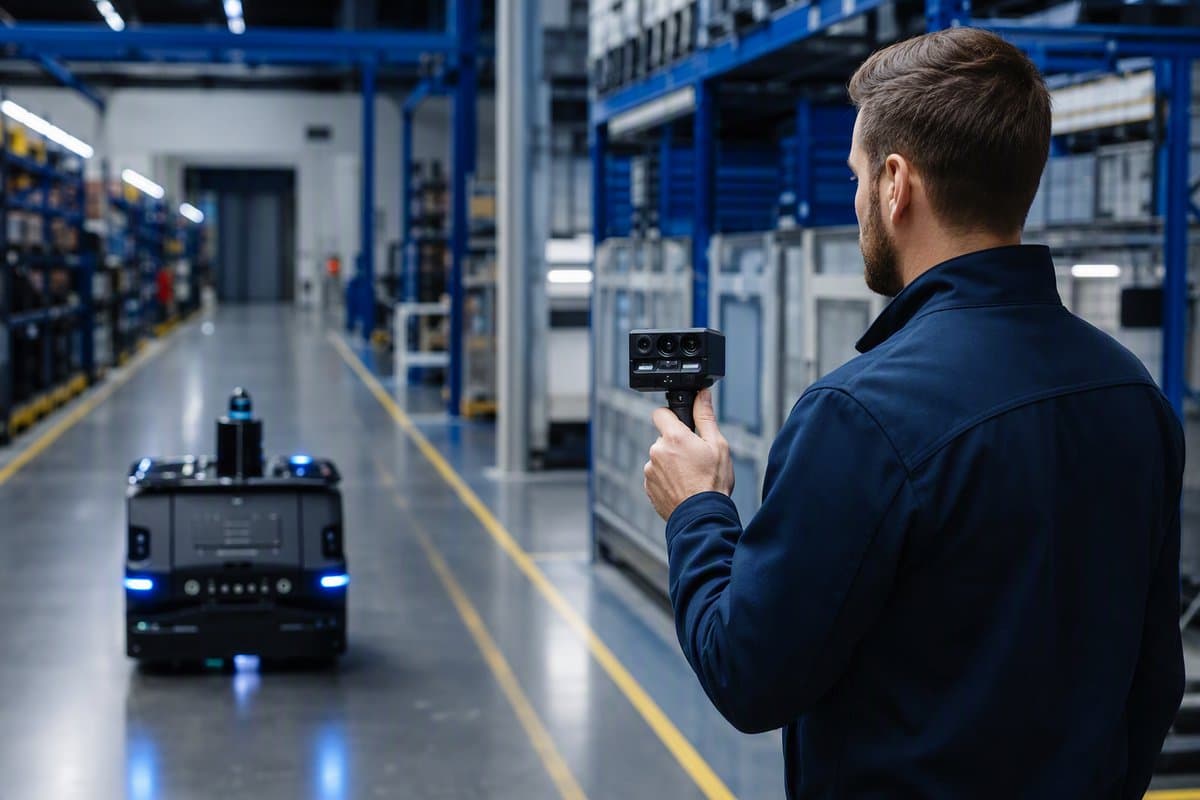
Visual Navigation & Embodied Perception
- The near-ring multi-camera layout preserves more complete spatial context, path information, and occlusion changes.
- Suited to continuous capture on mobile robots, wearables, and in complex environments.
- Ideal for building embodied perception datasets for indoor navigation, inspection, and human-robot collaboration.
World Model & Multimodal Training Data
- Synchronized multi-camera capture and local storage provide stable input for temporal prediction.
- Supports world model training and multimodal data organization, making it easy to accumulate continuous observation sequences.
- Helps build a unified data foundation for perception, prediction, and decision-making tasks.